Students learn forward/inverse kinematics, singularity analysis, and constraint-aware path
planning for modern robotic manipulators, implementing kinematic models and planners in a
final project.
- Professor: Aude Billard
- Professor: Durgesh Haribhau Salunkhe
- Professor: Arda Yigit
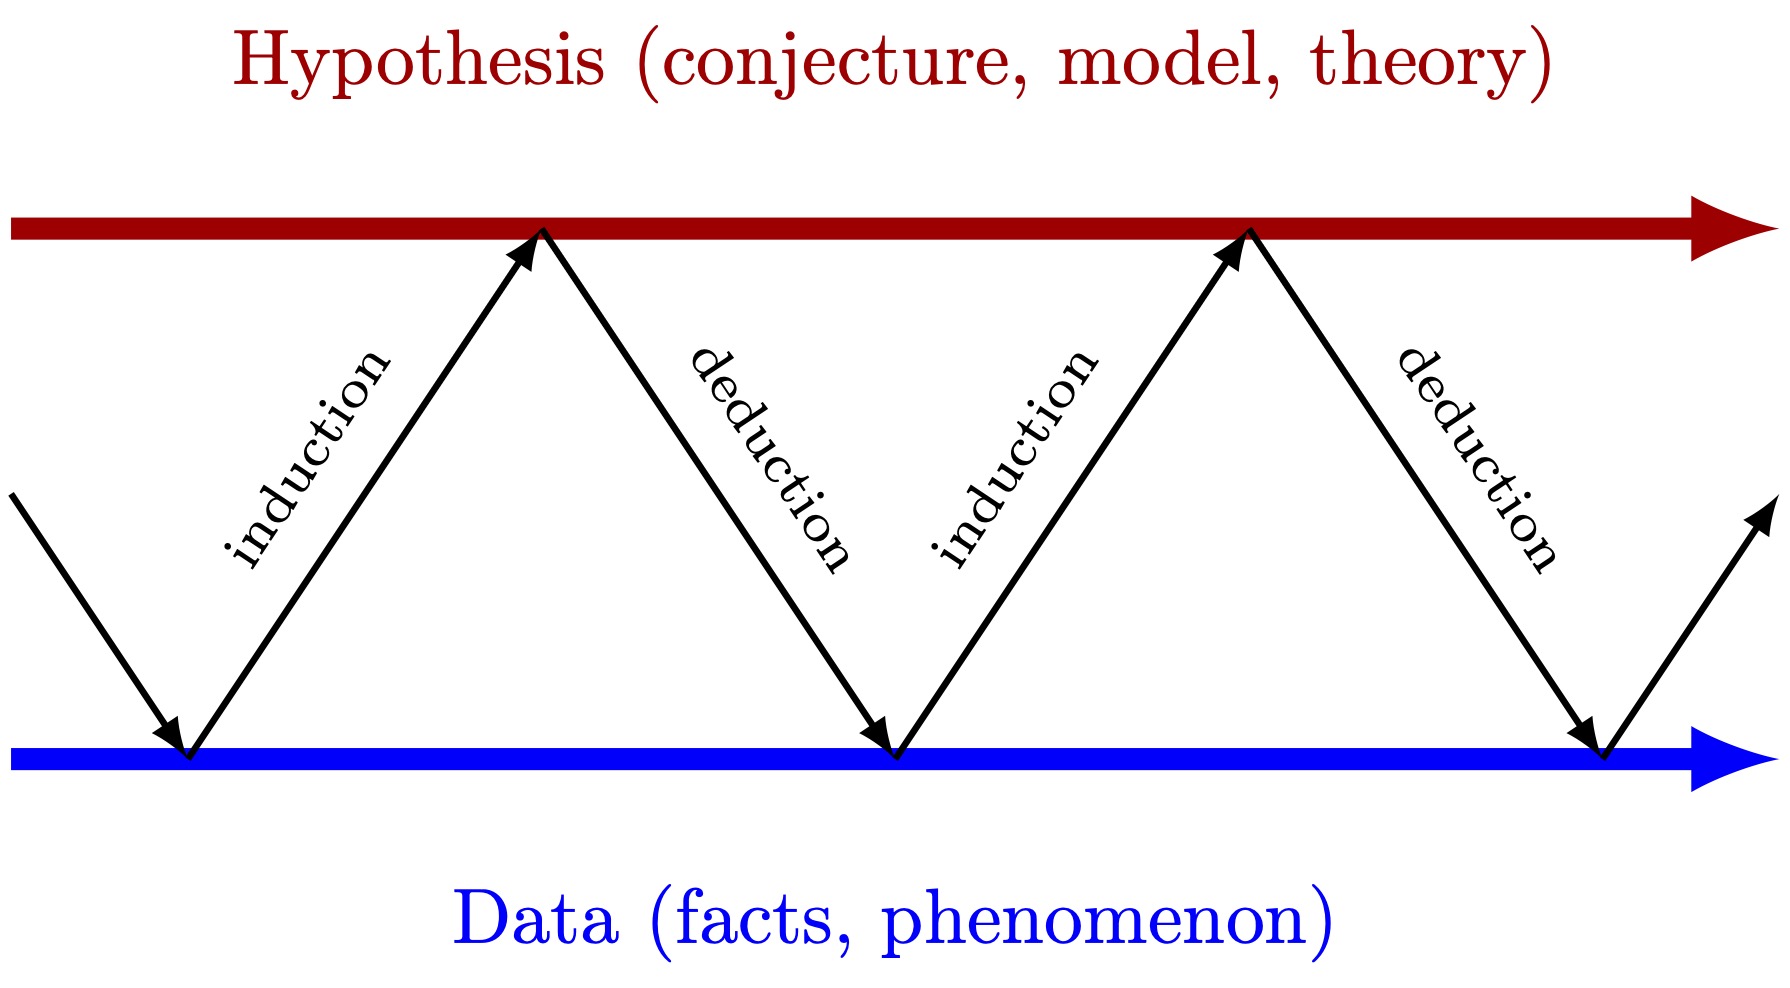
This course gives the fondamentals of the design of experiments
- Professor: Jean-Marie Fuerbringer